 Alp Ünlü
Worm Picker: A contact-sensing tool head
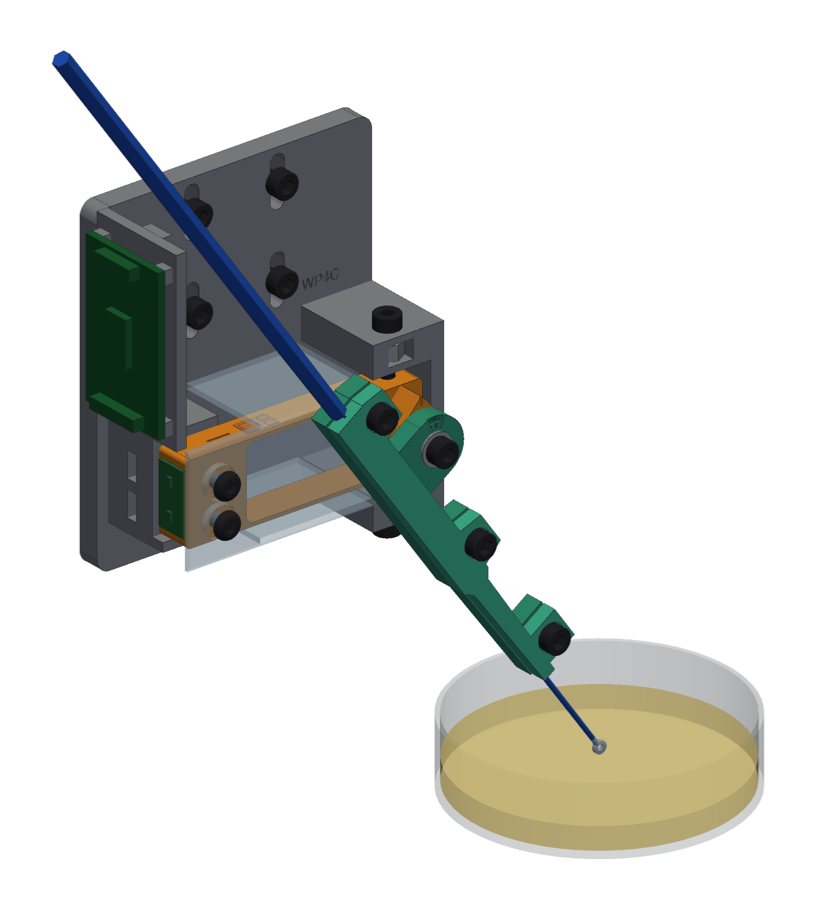
A tool head for an automated C. elegans picker that feels the moment it touches the agar.
Picking C. elegans means lowering a tiny loop onto soft agar without digging into it. For an automated picker, the machine has to know the exact moment the loop touches the surface, so the motor can stop right away.
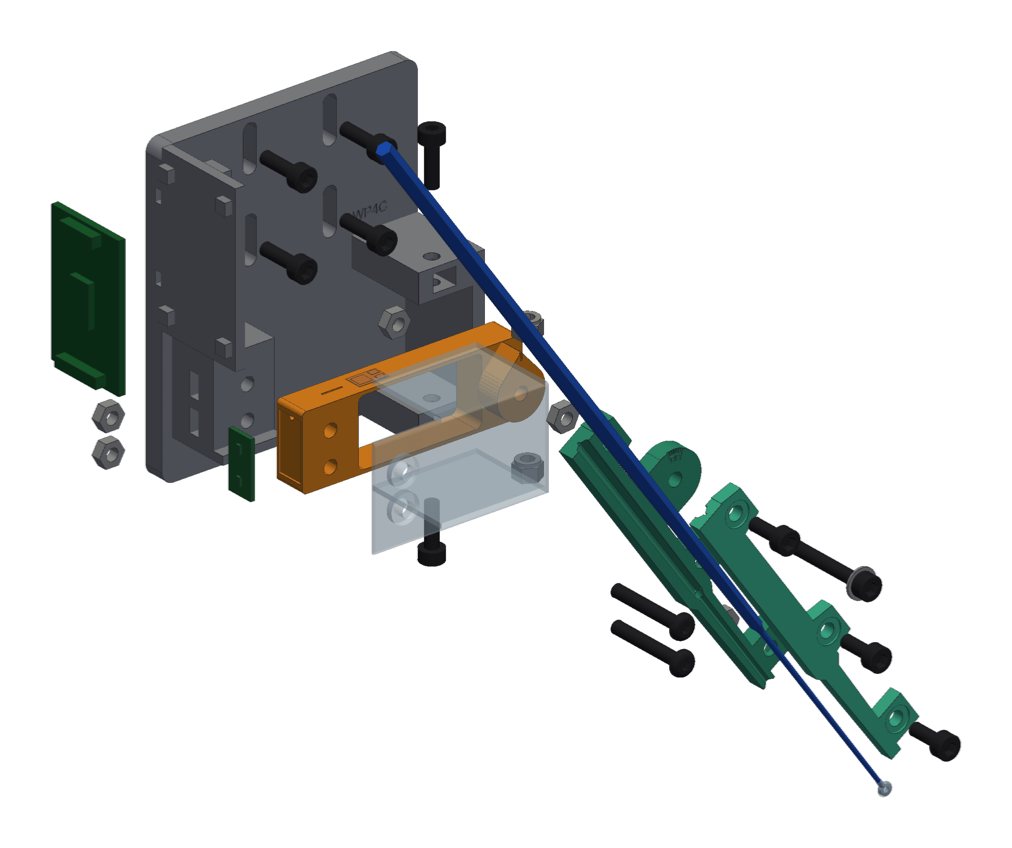
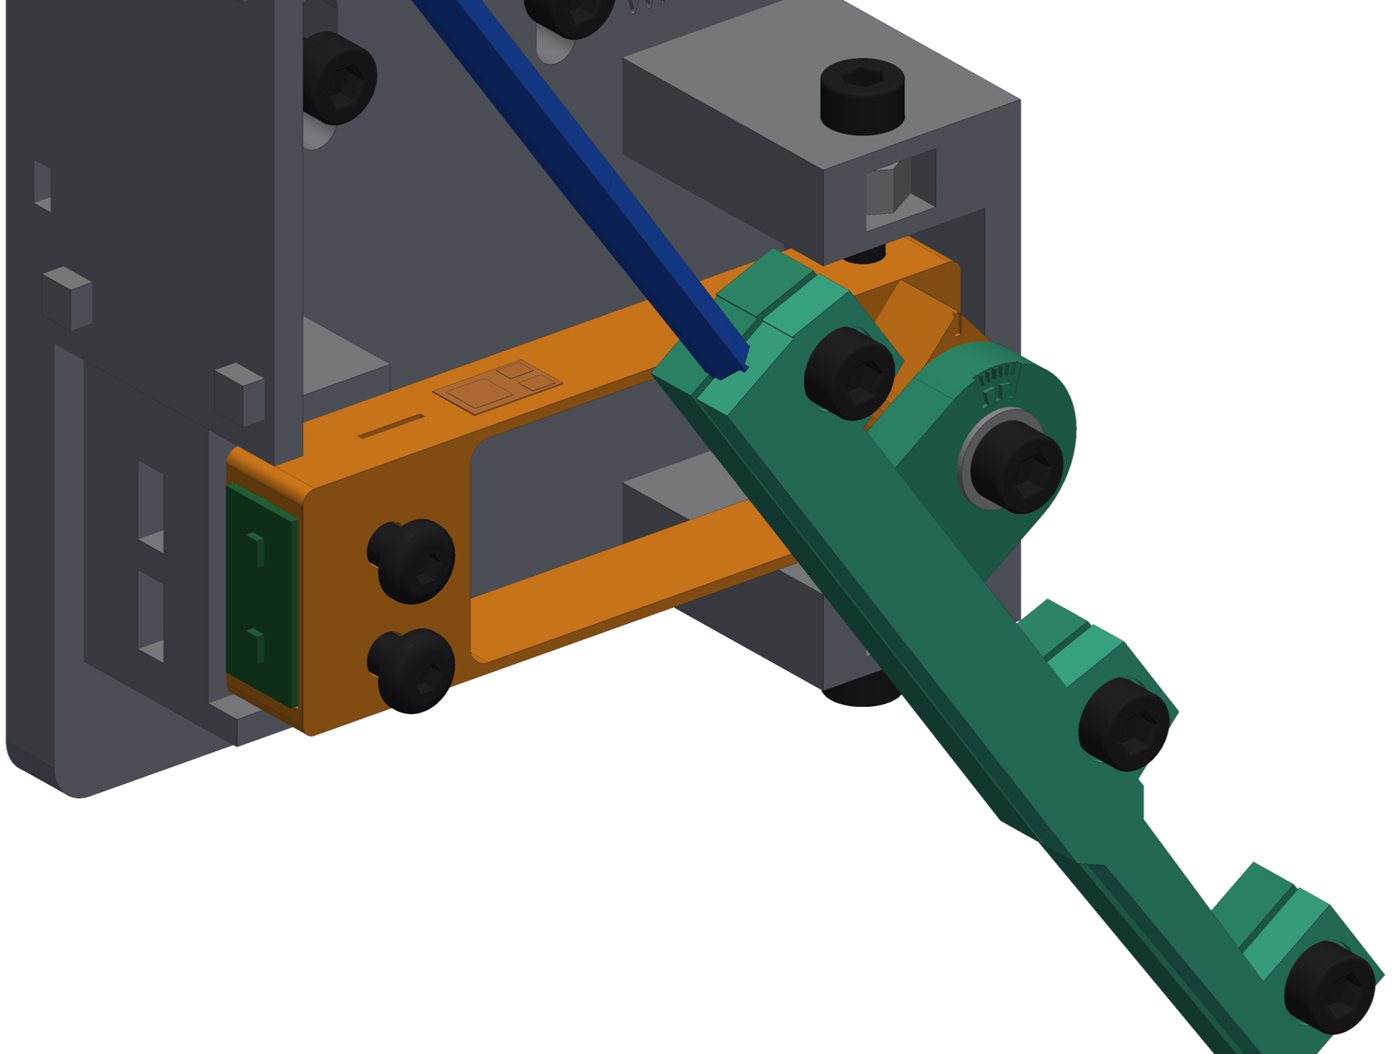
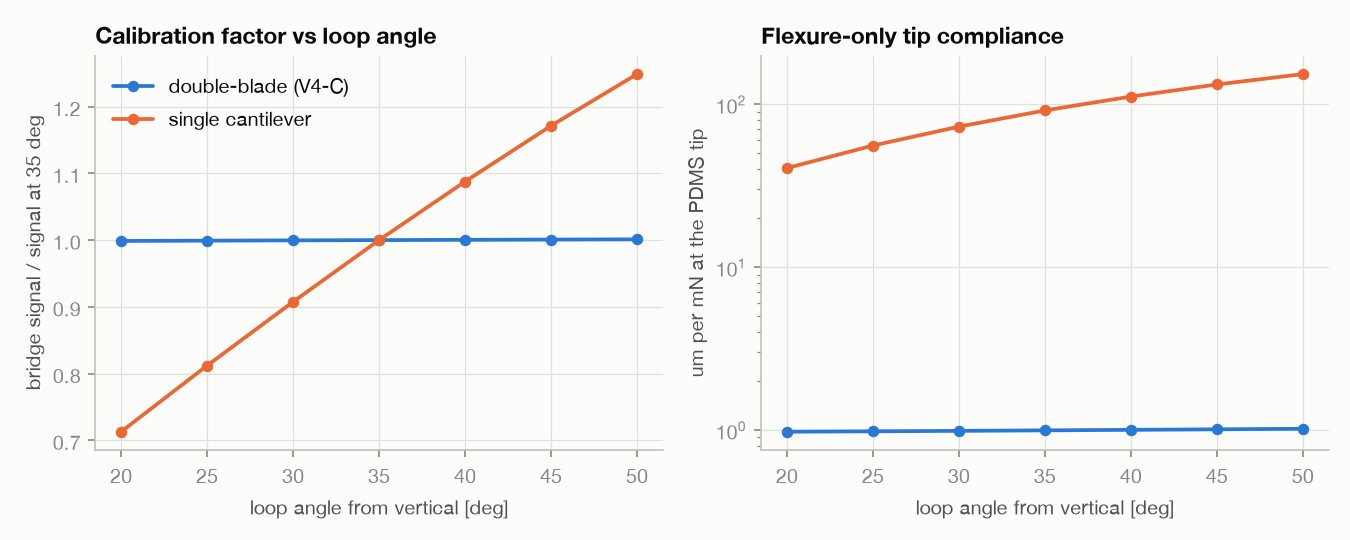
The heart of the design is a 3D-printed double-blade flexure: two thin blades join a fixed block and a moving block in a single print. When the loop touches the agar, the moving block shifts straight up without tilting, so the reading is the same whatever the loop angle or wherever the tip touches. Two strain gauges on the same blade form a half-bridge that cancels temperature drift.
The loop sits in a carrier at an adjustable angle of 20–50° and can be swapped in seconds while its tip returns to the same position. Alongside the CAD model I worked through the mechanics, signal and noise; the estimates put the touch threshold below one millinewton. The design is complete, but it has not been built and tested yet.